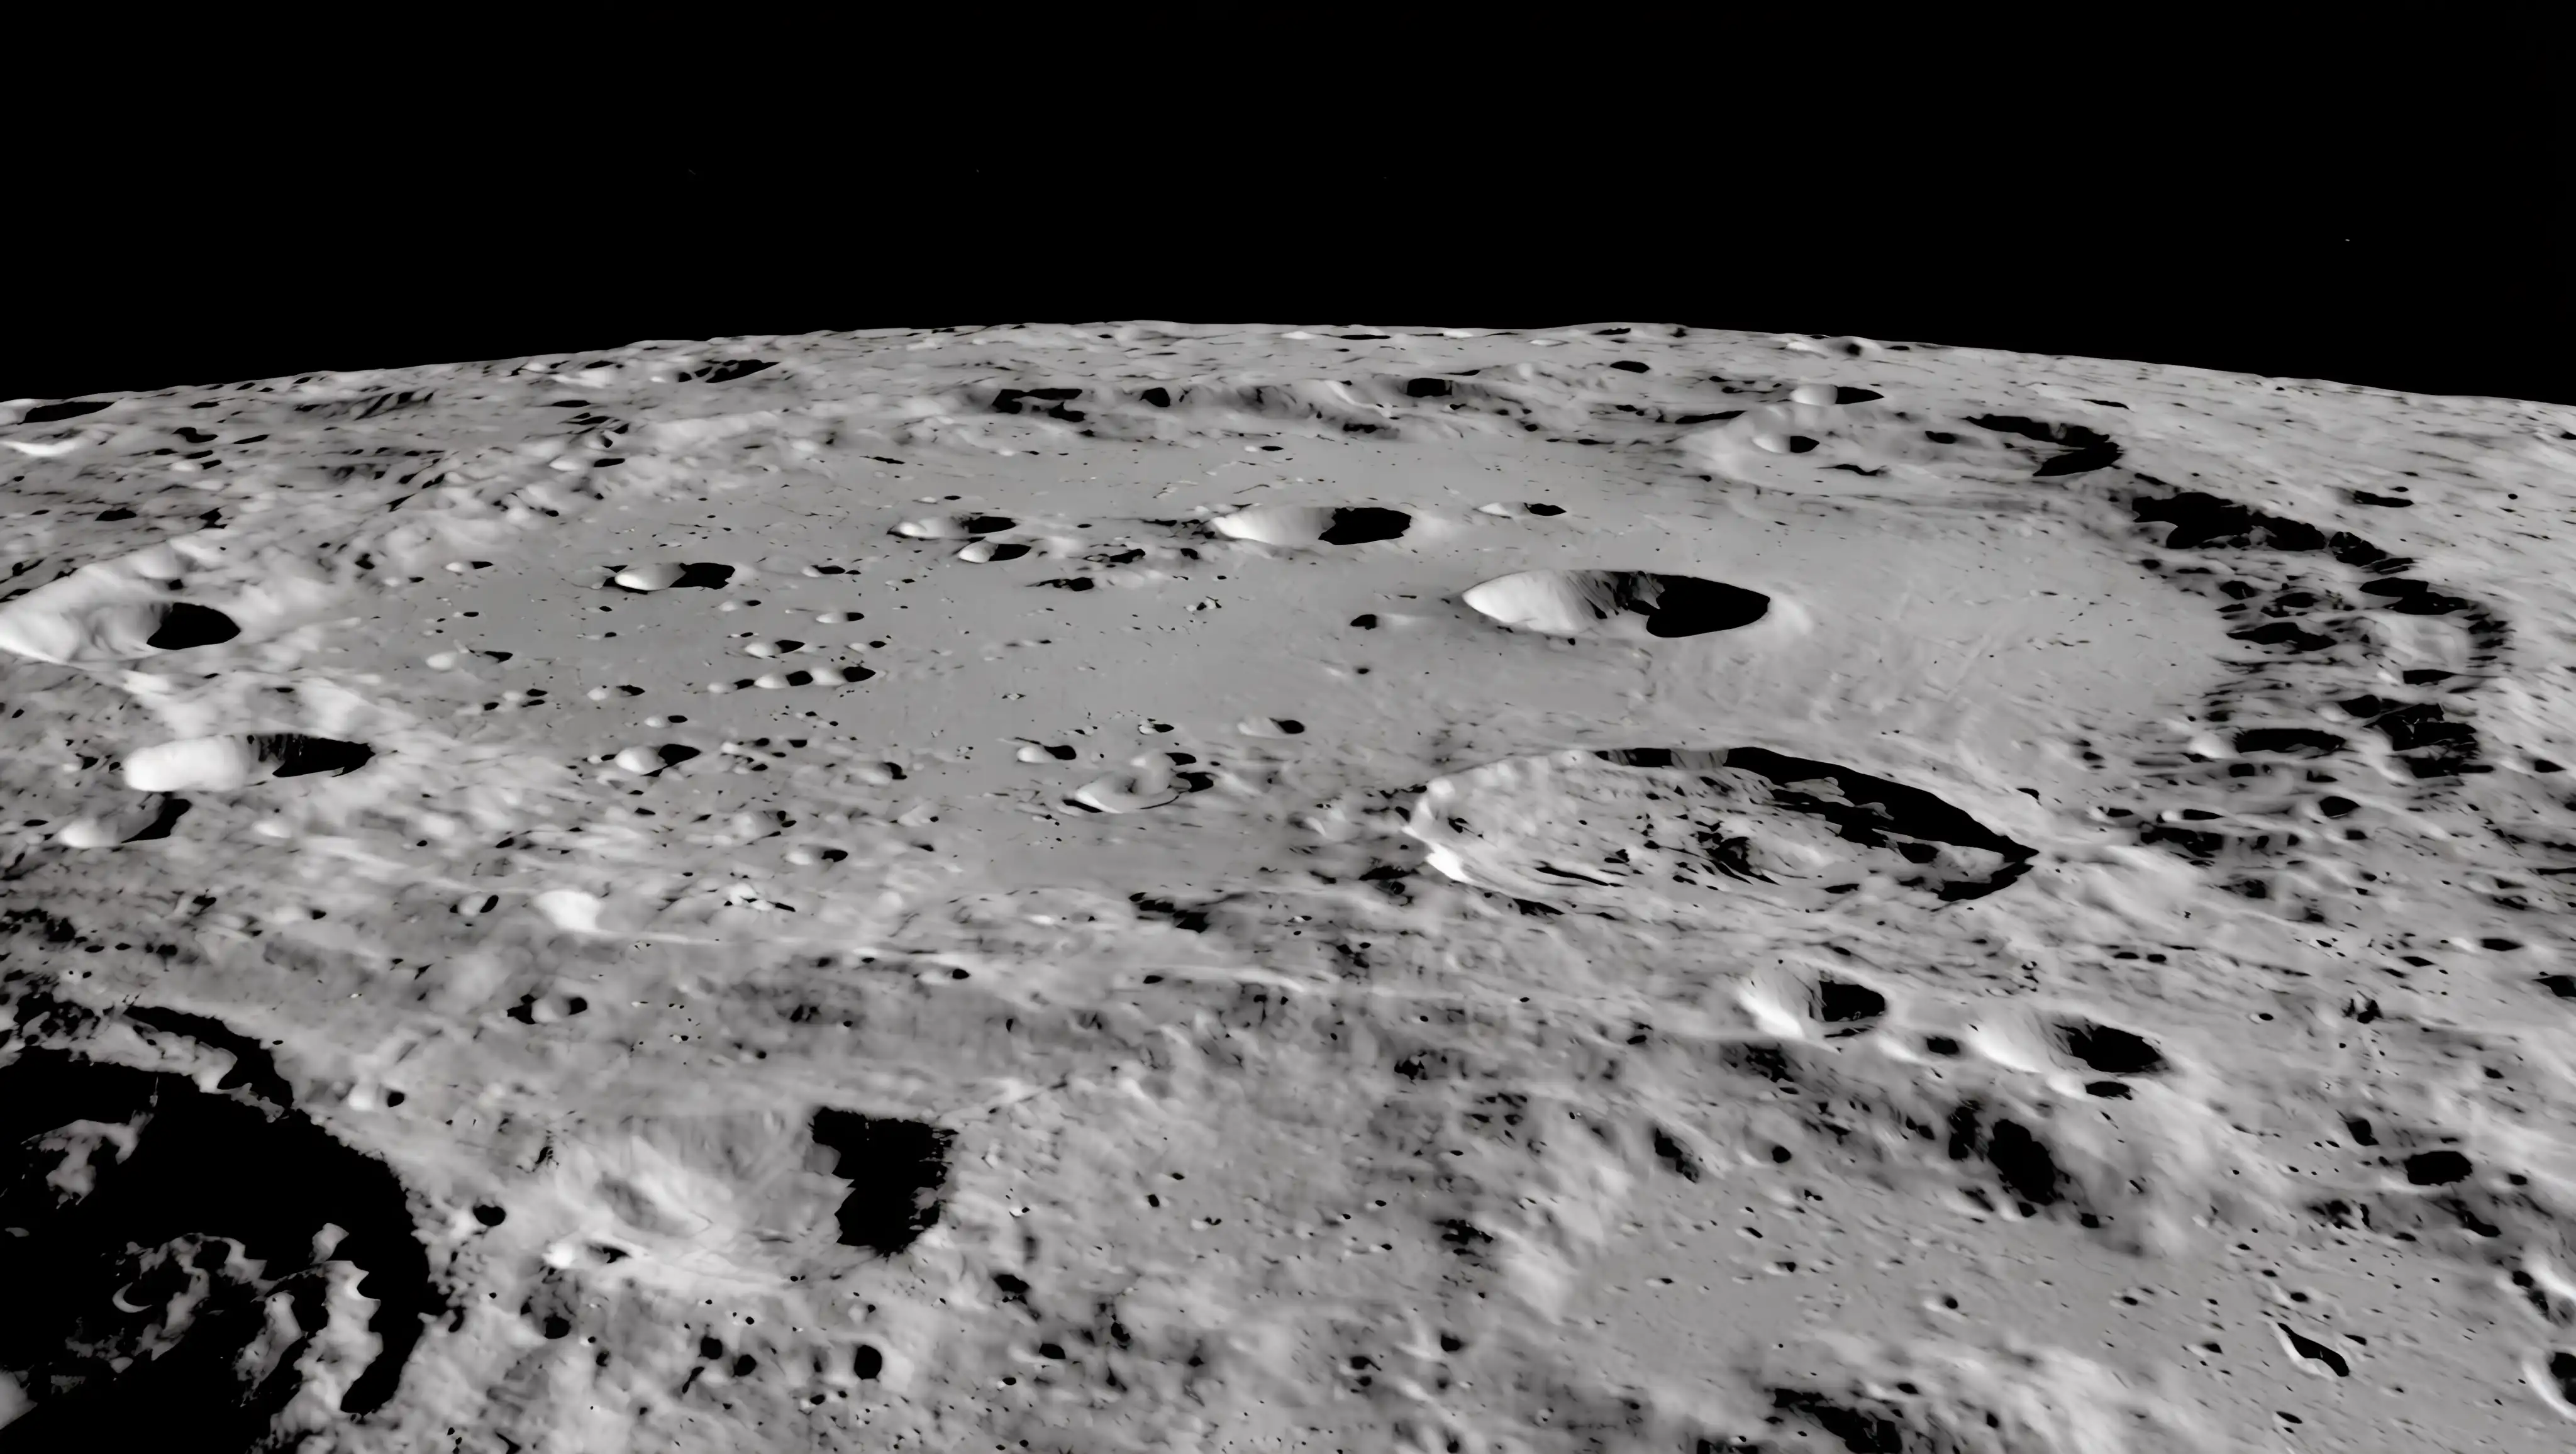
Lunar construction demands a different kind of system.
Building roads, landing pads, foundations, and prepared sites on the Moon will require significant material handling before humans can operate at scale.
Highly specialised machines can be highly capable, but also represent a singular point of failure. Centralised coordination is vulnerable to communication delays and changing environments.
EMERGENCE explores a different approach: a homogeneous robotic fleet using decentralised autonomy, where identical platforms can contribute to multiple construction roles at once.
Identical robots. Shared autonomy. Adaptive construction roles.
Each platform shares the same underlying architecture while contributing to the construction workflow according to local observations and current task demand.
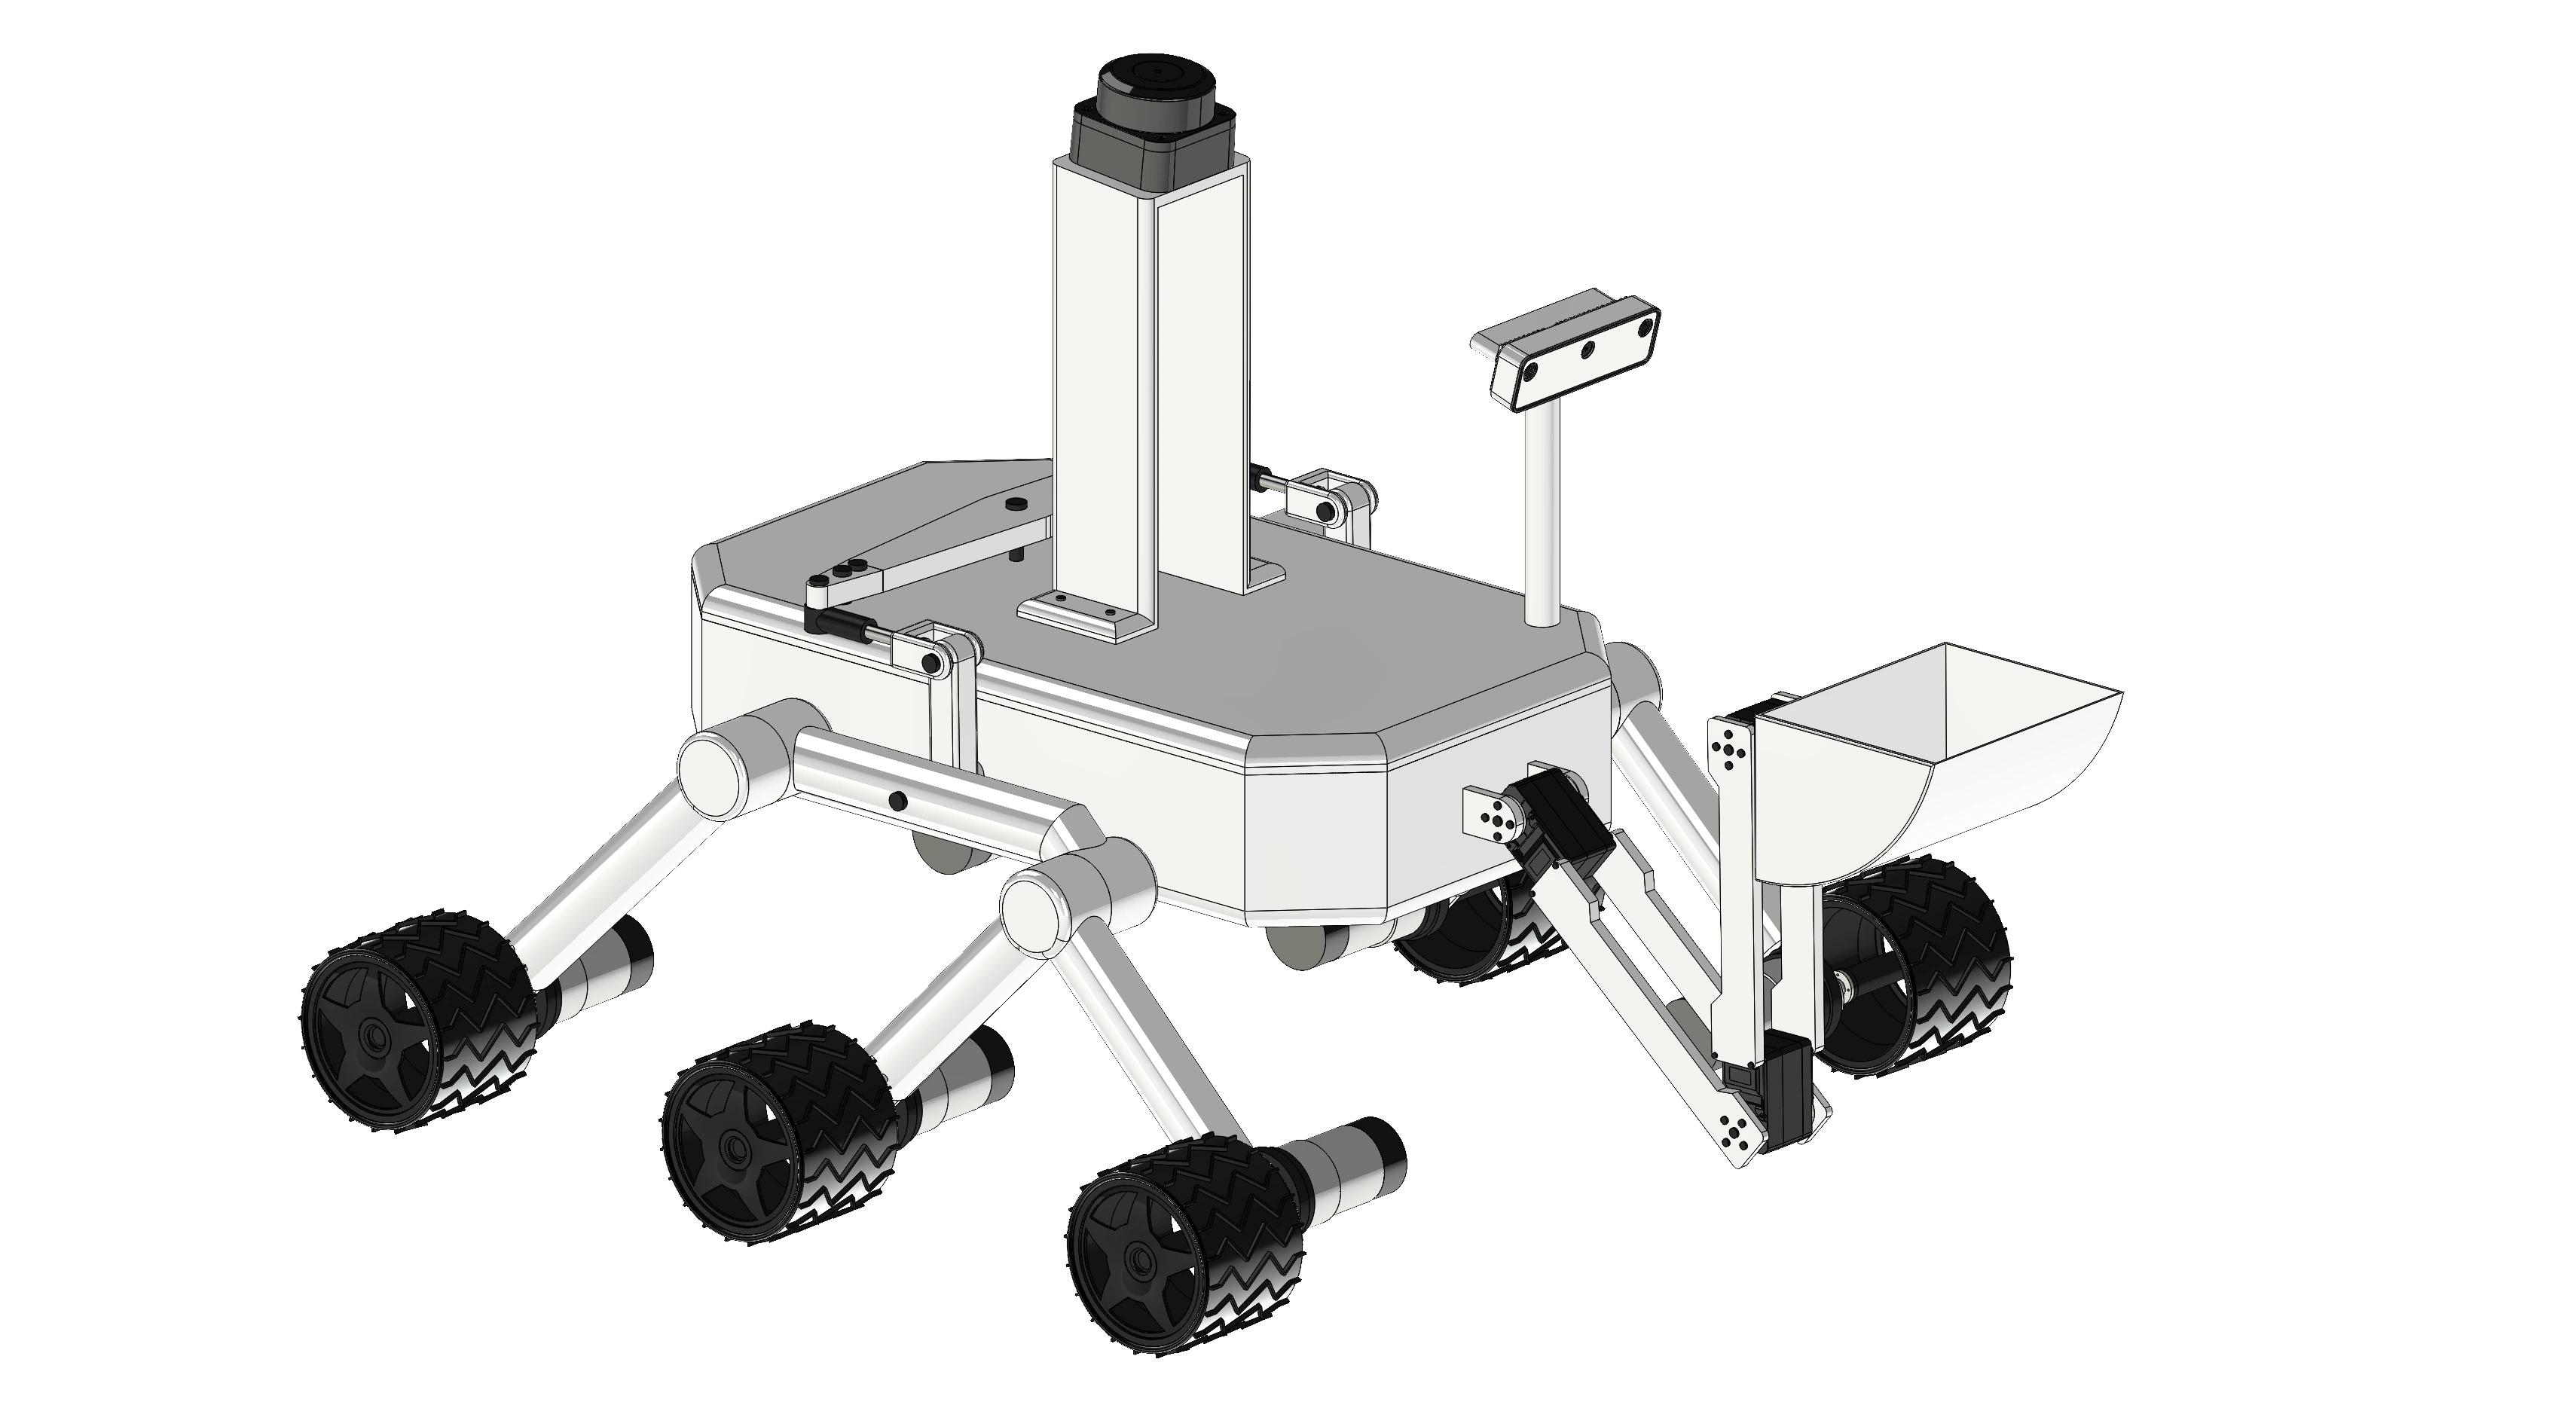
One platform designed around the construction workflow.
The robotic platform combines lunar mobility, manipulation, sensing and onboard computation in a common architecture intended to support multiple construction behaviours.
Roles emerge from the state of the system.
Rather than permanently assigning each robot a role, EMERGENCE is investigating shared reinforcement-learning policies that allow robots to select useful behaviours from their local observations and current construction demand.
Single-platform intelligence
- Single-agent PPO
- Custom simulation environment
Distributed swarm intelligence
- Multi-agent shared policy
- Decentralised execution
- Adaptive role allocation
- Failure and disturbance testing